Scope: This is a documentation-based hardware analysis. TVG Report has not tested this camera.
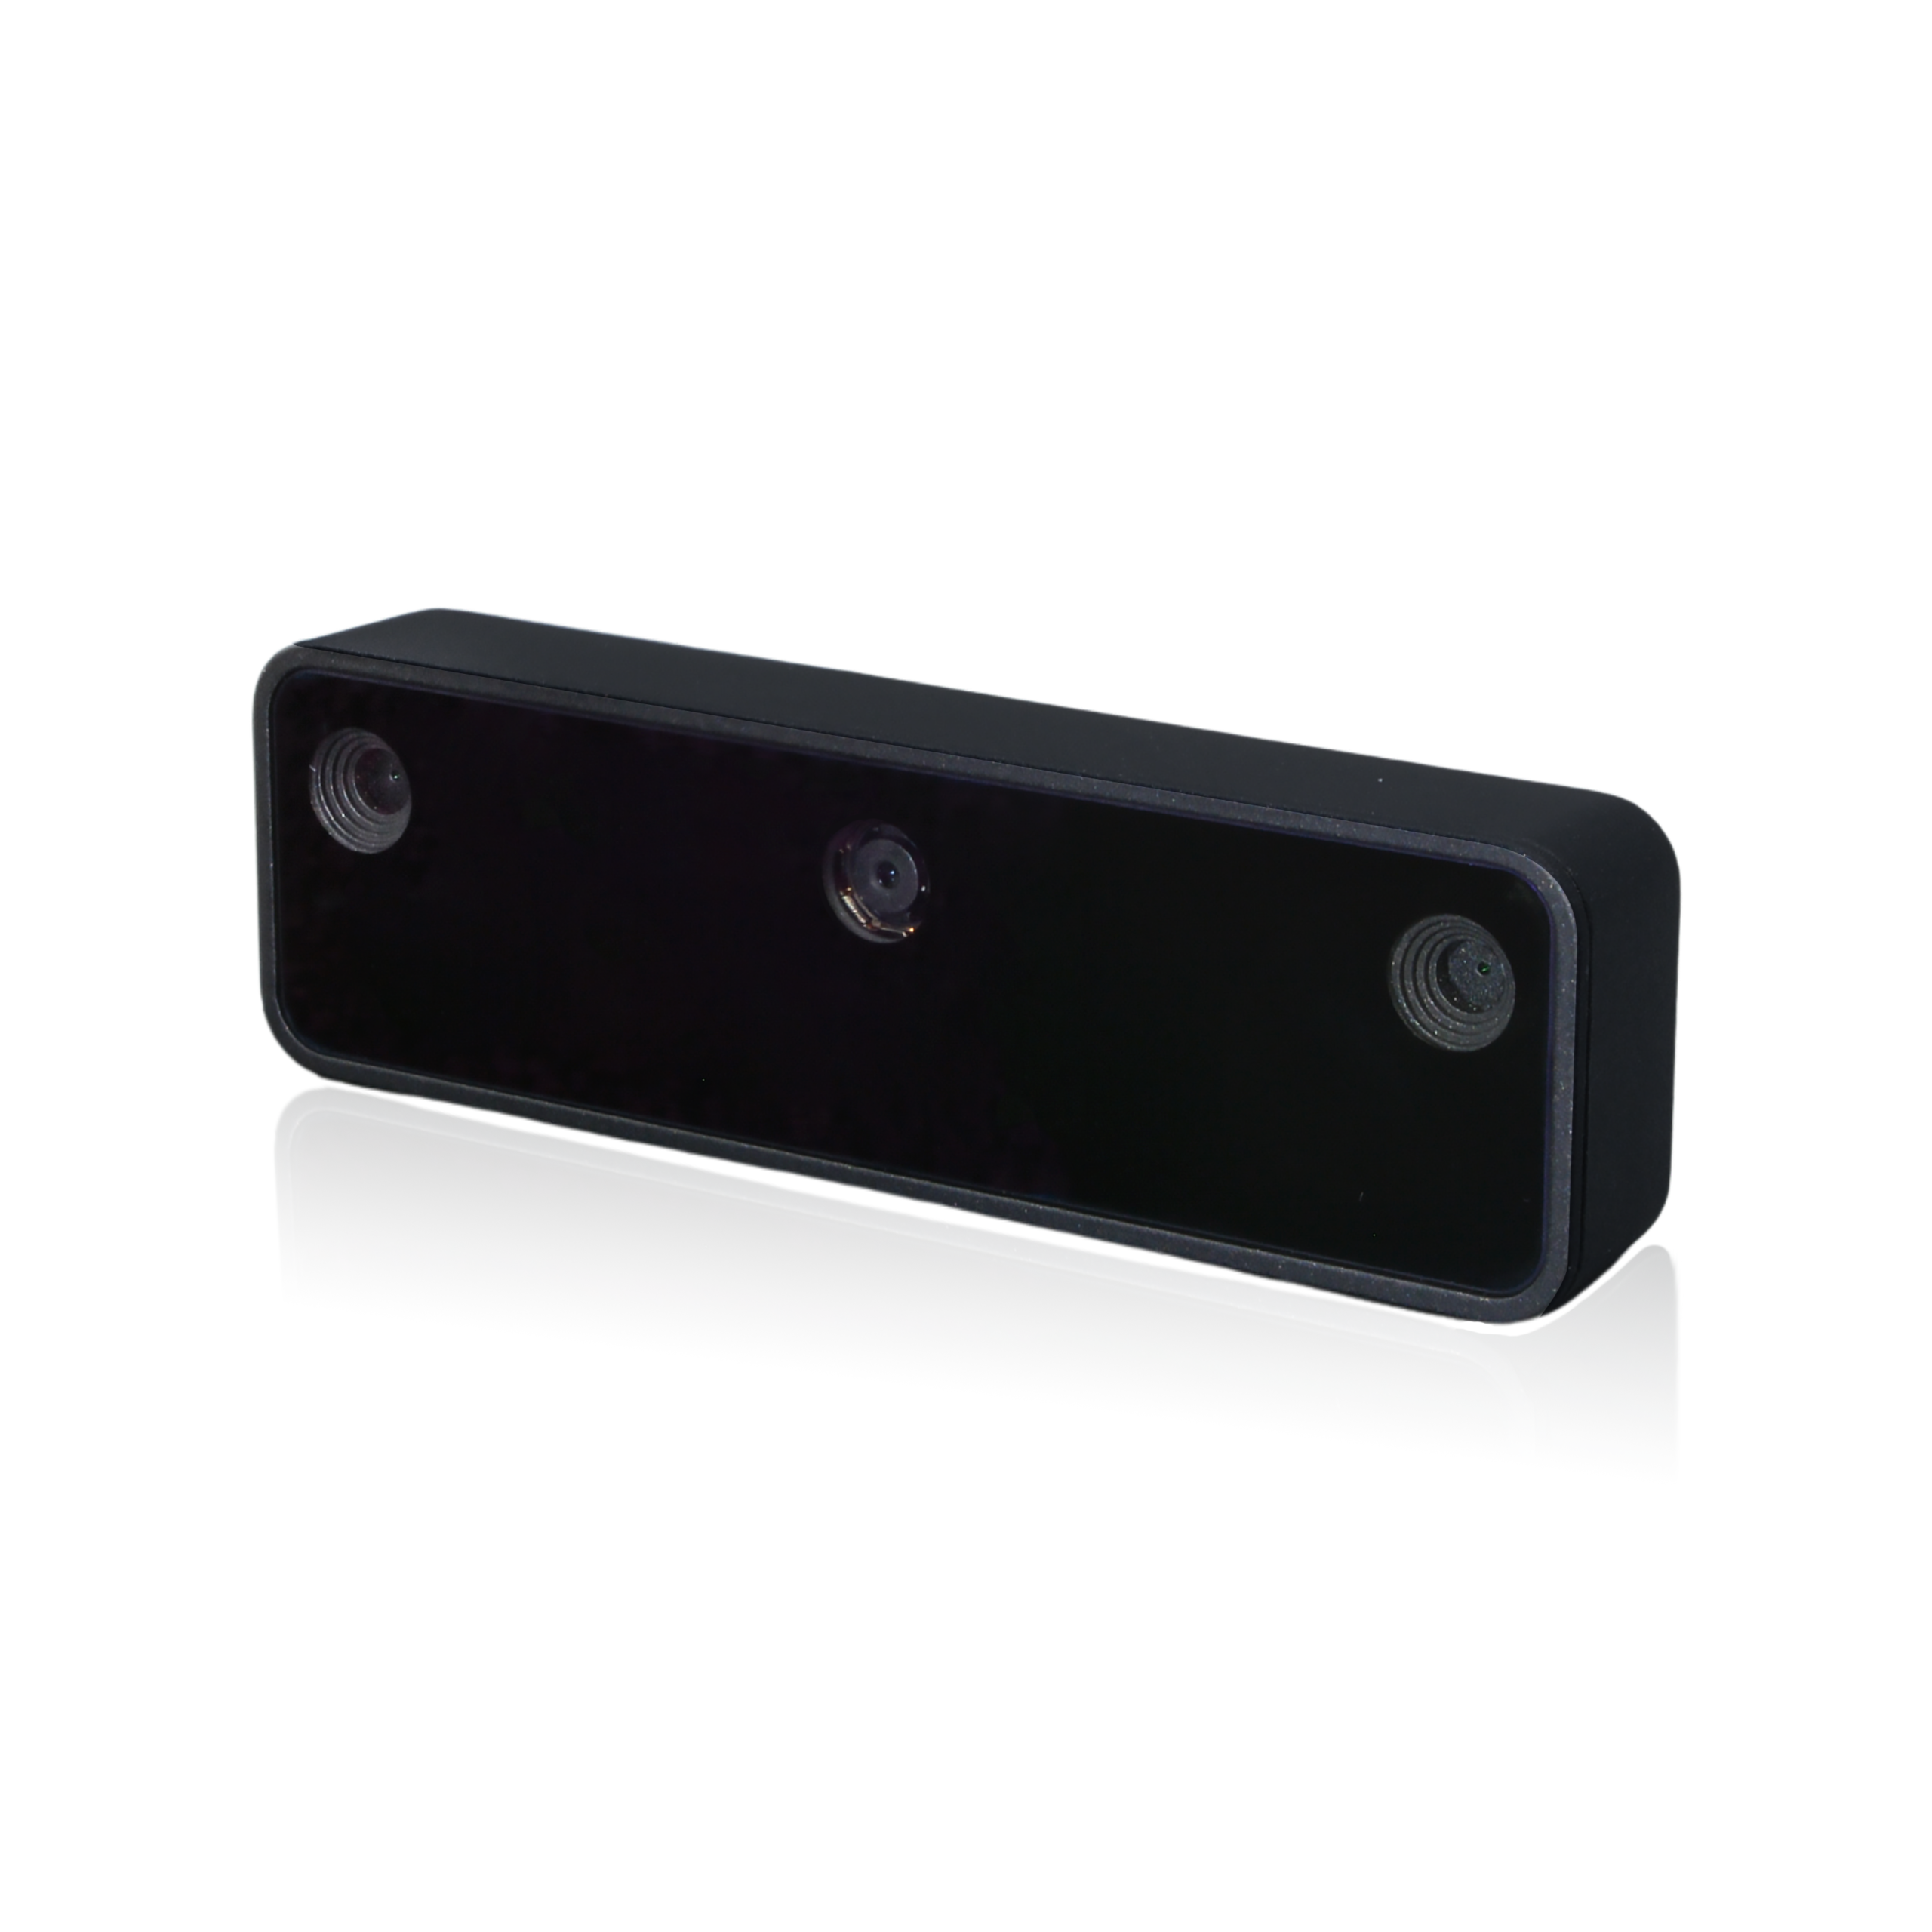
The Luxonis OAK-D Lite combines stereo depth cameras, a color camera and an RVC2 vision processor in a USB-connected module. Its main engineering value is not a claim that it is the “best” entry point to spatial AI. It is that DepthAI pipelines can run camera processing and neural-network workloads on the device before sending results to a host.
What stays on the camera
Luxonis documents the OAK-D Lite as an RVC2-based camera with stereo depth, a color sensor and on-device processing. A host still configures and consumes the pipeline through DepthAI, but image manipulation, depth processing and supported neural-network stages can run on the camera rather than placing every operation on a Raspberry Pi or laptop CPU.
That split can reduce host-side processing load, but the advertised RVC2 compute figure is not an application benchmark. Actual throughput depends on the model, camera streams, resolution, pipeline design and host connection.
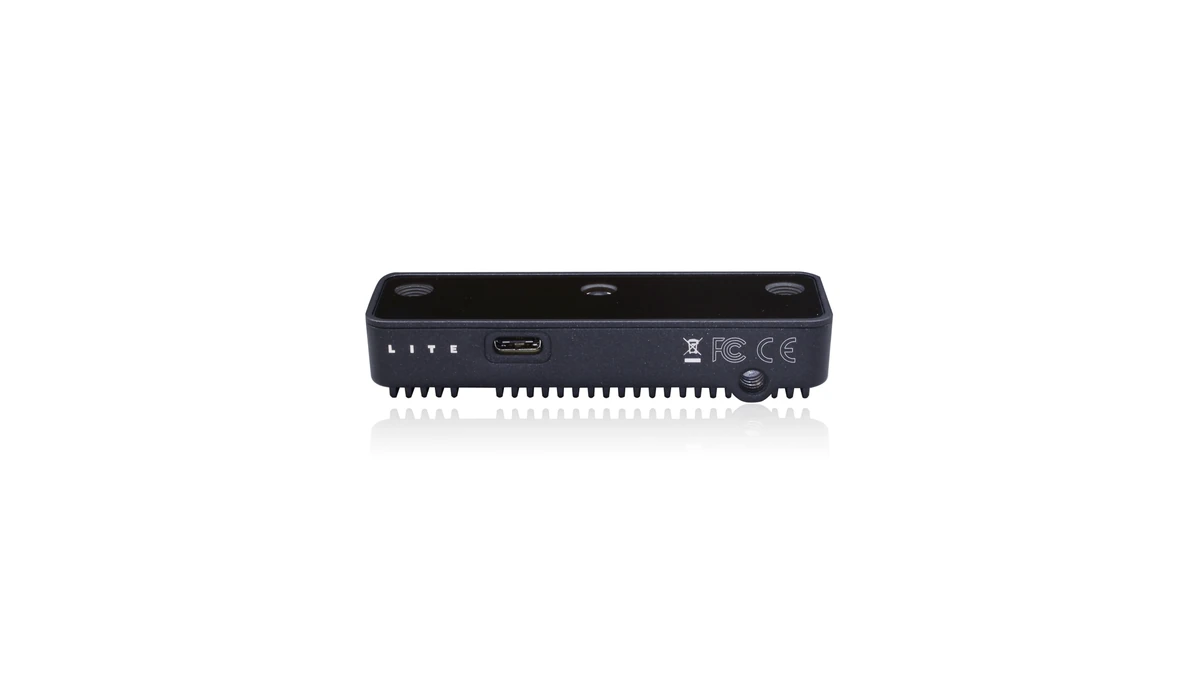
The depth hardware sets the working envelope
The module uses a fixed stereo-camera baseline, so mounting stability and an unobstructed view matter. Depth quality also depends on scene texture, lighting, range and calibration; the specification sheet alone cannot establish performance in a particular robot.
The color camera is offered in autofocus and fixed-focus variants. That choice mainly affects the RGB working distance and resistance to focus movement or vibration. It does not replace the separate stereo pair used for depth. Builders should select the exact variant around the intended mounting distance rather than treating AF and FF as a simple quality ranking.
Revision and integration checks
Current Luxonis documentation lists a BMI270 six-axis IMU, while older production history may differ. Confirm the exact unit and revision before designing around IMU availability. The same rule applies to focus type and supplied cable.
Before committing a robot design, check:
- the exact AF or FF SKU and its intended working distance;
- USB bandwidth, host support and available power;
- mount rigidity, cable strain relief and camera clearance;
- the DepthAI version and example pipeline that will be maintained;
- whether the enclosure and operating environment fit the deployment.
What the specifications cannot establish
Public documentation can confirm interfaces, sensors, software access and the processing architecture. It cannot prove depth accuracy in a specific scene, long-run thermal behavior inside a robot enclosure, cable reliability, setup time or classroom durability. Those questions require a defined test on the exact hardware revision.
For builders comparing camera architectures rather than one product, TVG’s Raspberry Pi AI Camera versus OAK-D Lite guide separates monocular AI-camera and stereo-depth use cases.