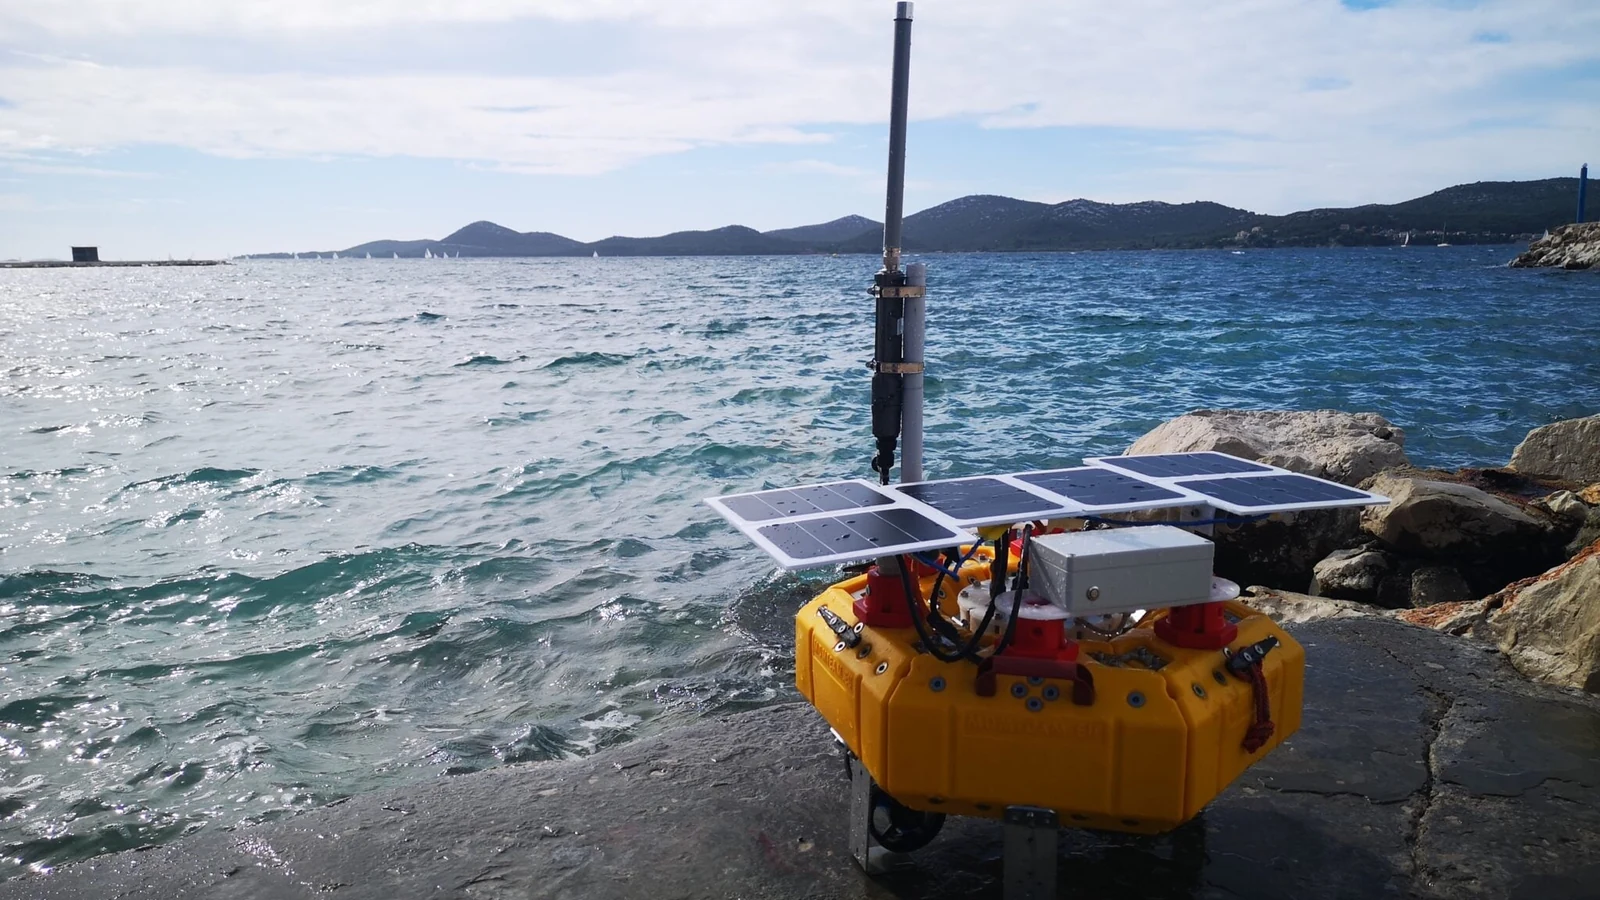
Marine robots rarely fail in convenient places. Saltwater, pressure, impacts and long travel times can turn a minor electronics fault into a lost field day. Italian marine-robotics developer MDM Team has documented a practical response: build platforms that can be repaired and reconfigured with accessible commercial parts, while reserving custom engineering for the parts that must survive the sea.
Two documented platforms, two different jobs
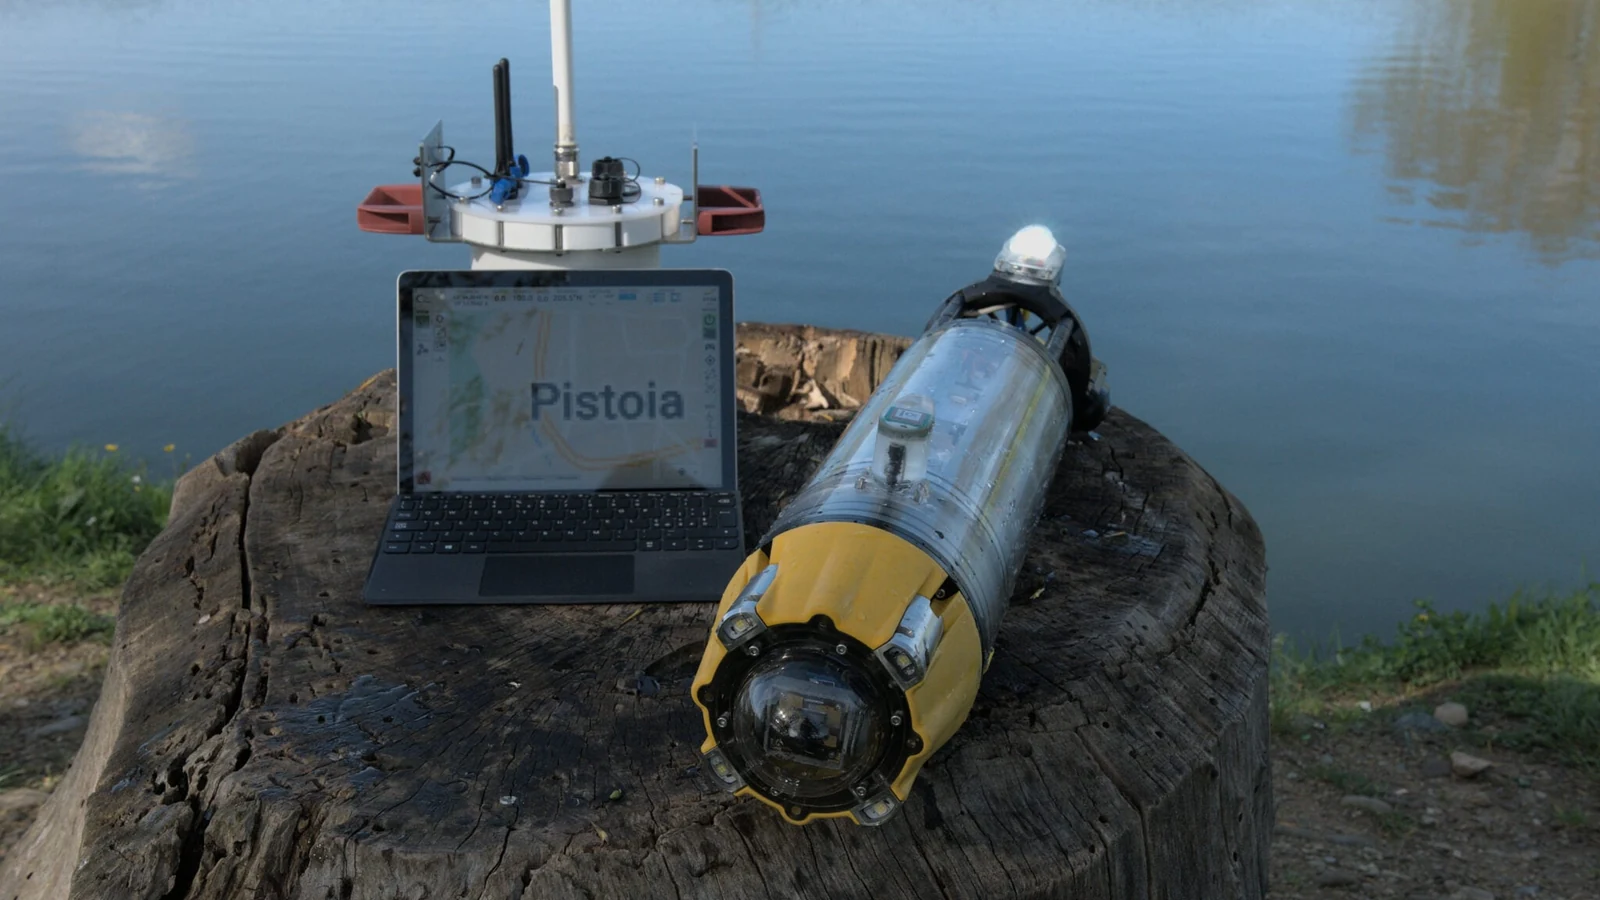
Raspberry Pi’s project profile describes STOK as a portable underwater vehicle used for inspection and environmental work. A Raspberry Pi 4 runs BlueOS, while a Pixhawk-class controller handles real-time vehicle control. That split matters: the Pi provides a familiar Linux computer for video, networking and application software, but it is not presented as the sole safety-critical controller.
The same profile describes CARIDDI as an unmanned surface vessel for water-quality and survey missions. It uses Raspberry Pi 5 with open-source software and carries different sensors according to the job. These are reported project configurations, not TVG tests, and performance depends on the complete mechanical, electrical and communications system.
Where commercial parts help
Using a widely available computer can shorten replacement time, simplify software development and make it easier to add cameras, storage or network interfaces. BlueOS also gives developers an established web-based environment for marine vehicles. Standard parts are especially valuable when a team needs to repair equipment away from its workshop.
That does not make a Raspberry Pi marine-ready by itself. Pressure housings, seals, cable penetrators, corrosion control, power conversion, thermal management and recovery procedures remain specialist work. Commercial off-the-shelf parts lower the cost of selected subsystems; they do not remove the need for environmental qualification.
The engineering lesson
Repairability comes from architecture, not one board. A useful design separates replaceable compute and sensor modules from watertight structure and deterministic control, documents connectors and software images, and keeps recovery options independent of the main computer. Field spares only help when the team can identify a fault, restore a known software image and pressure-check any opened enclosure before redeployment. A connector map, spare seals and a recovery checklist may be as important as the replacement computer. MDM Team’s published work shows that Raspberry Pi and other commercial components can support that approach. It does not establish that every low-cost part is suitable for every depth, duration or mission.